CAN bus: vehicle data explained
CAN bus allows a vehicle's electronic control units to exchange messages. Zenit can use only signals exposed by the vehicle and made compatible by the device, protocol and configuration; fuel, engine hours, status and diagnostics are not universal data points.
- Conditional dataCAN bus does not guarantee the same signal across every vehicle or specification.
- Author
- Zenit Telematics
- Published
- Updated
How does a CAN bus work, and which vehicle data can be read?
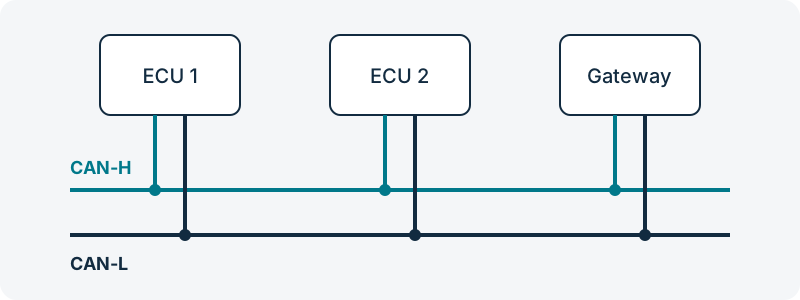
Control units share messages over the network. High-speed CAN uses the differential CAN-H and CAN-L lines; application data availability depends on the vehicle.
How do control units communicate?
Message identifiers participate in bus arbitration. Signal content needs the correct protocol and definition. Connecting to the network does not expose every possible value: access, decoding, security and installation need a vehicle-specific assessment. The diagram shows a conceptual topology rather than wiring instructions.
CAN bus on trucks and fleets: which signals should be checked?
| Potential data | Operational use | Limitation to check |
|---|---|---|
| Mileage and engine hours | Utilisation and maintenance thresholds | Counter source, units and continuity |
| Fuel use and level | Trends and exceptions to investigate | Exposed signal, resolution and measurement conditions |
| Engine and power take-off state | Separate stationary waiting from work | Signal availability and body equipment |
| Diagnostic indications | Start a technical investigation | A code does not replace workshop diagnosis |
Which standards describe CAN and heavy-vehicle networks?
Standards define communications and protocols; they do not prove which signals Zenit can read on one vehicle, which remains a compatibility check.
ISO 11898 family
ISO publishes the CAN-family standards for high-speed serial communication.
SAE J1939
SAE J1939 describes a communications family used in heavy-vehicle applications; parameter availability and mapping remain specific to the vehicle and integration.
Frequently asked questions about CAN bus and vehicle data
Concise answers about available signals, accuracy and the difference from an external sensor.
Which data can CAN bus provide?
It may expose signals such as mileage, engine hours, engine state, fuel use or tank level, but the actual list depends on the vehicle, ECU, protocol, device and configuration. No signal should be treated as universal.
Does CAN bus always measure fuel with the same accuracy?
No. Availability, resolution and data quality vary across vehicles and installations. A telematics value must be checked on the vehicle and against its intended use; it is not automatically a certified measurement.
Are CAN bus and an external fuel sensor the same?
No. CAN bus uses signals made available by the vehicle's control units; an external sensor adds a dedicated measurement. The choice depends on compatibility, purpose, installation and calibration options and requires technical validation.
How can these concepts be applied to fleet management?
Connect “CAN bus” with vehicle administration and daily operational control.
Costs, documents and deadlines
Apply “CAN bus” to daily work by connecting vehicle costs, documents, maintenance and deadlines.
Positions, journeys and alerts
Review “CAN bus” alongside positions, journeys, drivers and alerts to choose the control and its owner.
Validate signals and purpose on the actual vehicle.
A demo clarifies which signals are available, how they are interpreted and which limits apply before they are used for fuel analysis, maintenance or a formal challenge.
- No guaranteed savingsData becomes priorities, not promises.